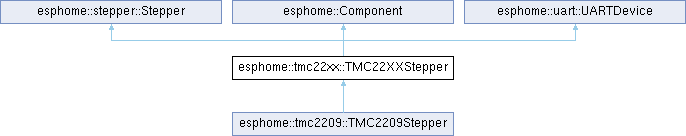
Base class for Trinamic stepper drivers that are configured over the single wire UART interface. More...
#include <tmc22xx.h>
Public Member Functions | |
| void | setup () override |
| void | loop () override |
| void | dump_config () override |
| void | on_shutdown () override |
| float | get_setup_priority () const override |
| void | set_address (uint8_t address) |
| void | set_enn_pin (GPIOPin *pin) |
| void | set_step_pin (GPIOPin *pin) |
| void | set_dir_pin (GPIOPin *pin) |
| void | set_index_pin (InternalGPIOPin *pin) |
| void | set_diag_pin (InternalGPIOPin *pin) |
| void | set_clock_frequency (uint32_t frequency) |
| void | set_rsense (float rsense) |
| void | set_vsense (bool vsense) |
| void | set_ottrim (uint8_t ottrim) |
| void | set_analog_current_scale (bool enable) |
| void | set_initial_run_current (float current) |
| void | set_initial_hold_current (float current) |
| void | set_initial_microsteps (uint16_t microsteps) |
| void | set_enabled (bool enabled) |
| Enable or disable the motor outputs, using the ENN pin when configured and TOFF otherwise. | |
| bool | is_enabled () const |
| bool | is_unreachable () const |
| True while the driver does not answer, until the status poll reads it again (every 10 s). | |
| template<typename F > | |
| void | add_on_status_callback (F &&callback) |
| Called with the condition and whether it became active or cleared. | |
| void | set_microsteps (uint16_t microsteps) |
| uint16_t | get_microsteps () |
| void | set_interpolation (bool enable) |
| void | set_spreadcycle (bool enable) |
| void | set_inverse_direction (bool inverse) |
| void | set_tpwm_threshold (uint32_t threshold) |
| void | set_run_current (float current) |
| Set the motor run or hold current in A RMS. | |
| void | set_hold_current (float current) |
| void | set_irun (uint8_t irun) |
| void | set_ihold (uint8_t ihold) |
| void | set_iholddelay (uint8_t delay) |
| void | set_tpowerdown (uint8_t tpowerdown) |
| void | set_standstill_mode (StandstillMode mode) |
| void | set_toff (uint8_t toff) |
| Chopper off time (1-15). TOFF=0 is used to disable the outputs, so this is applied on the next enable. | |
| void | set_tbl (uint8_t tbl) |
| void | set_hend (uint8_t hend) |
| void | set_hstrt (uint8_t hstrt) |
| void | set_pwm_ofs (uint8_t ofs) |
| void | set_pwm_grad (uint8_t grad) |
| void | set_pwm_freq (uint8_t freq) |
| void | set_pwm_autoscale (bool enable) |
| void | set_pwm_autograd (bool enable) |
| void | set_pwm_reg (uint8_t reg) |
| void | set_pwm_lim (uint8_t lim) |
| float | scale_to_current (uint8_t scale) |
| Convert a current scale (0-31) to A RMS, without analog current scale. | |
| bool | write_register (uint8_t reg, uint32_t value) |
| optional< uint32_t > | read_register (uint8_t reg) |
| bool | write_field (const RegisterField &field, uint32_t value) |
| optional< uint32_t > | read_field (const RegisterField &field) |
 Public Member Functions inherited from esphome::stepper::Stepper | |
| void | set_target (int32_t steps) |
| void | report_position (int32_t steps) |
| void | set_acceleration (float acceleration) |
| void | set_deceleration (float deceleration) |
| void | set_max_speed (float max_speed) |
| virtual void | on_update_speed () |
| bool | has_reached_target () |
| Public Member Functions inherited from esphome::Component | |
| float | get_actual_setup_priority () const |
| void | set_setup_priority (float priority) |
| void | call () |
| virtual void | on_safe_shutdown () |
| virtual bool | teardown () |
| Called during teardown to allow component to gracefully finish operations. | |
| virtual void | on_powerdown () |
| Called after teardown is complete to power down hardware. | |
| uint8_t | get_component_state () const |
| void | reset_to_construction_state () |
| Reset this component back to the construction state to allow setup to run again. | |
| bool | is_in_loop_state () const |
| Check if this component has completed setup and is in the loop state. | |
| bool | is_idle () const |
| Check if this component is idle. | |
| void | mark_failed () |
| Mark this component as failed. | |
| void | mark_failed (const LogString *message) |
| void | disable_loop () |
| Disable this component's loop. | |
| void | enable_loop () |
| Enable this component's loop. | |
| void | enable_loop_soon_any_context () |
| Thread and ISR-safe version of enable_loop() that can be called from any context. | |
| bool | is_failed () const |
| bool | is_ready () const |
| virtual bool | can_proceed () |
| bool | status_has_warning () const |
| bool | status_has_error () const |
| void | status_set_warning () |
| void | status_set_warning (const char *message) |
| void | status_set_warning (const LogString *message) |
| void | status_set_error () |
| void | status_set_error (const LogString *message) |
| void | status_clear_warning () |
| void | status_clear_error () |
| ESPDEPRECATED ("Use status_momentary_warning() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_warning(const char *name | |
| void | status_momentary_warning (uint32_t length=5000) |
Set warning status flag and clear it after length ms. | |
| void | status_momentary_warning (const LogString *message, uint32_t length=5000) |
| ESPDEPRECATED ("Use status_momentary_error() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_error(const char *name | |
| void | status_momentary_error (uint32_t length=5000) |
Set error status flag and clear it after length ms. | |
| void | status_momentary_error (const LogString *message, uint32_t length=5000) |
| bool | has_overridden_loop () const |
| const LogString * | get_component_log_str () const ESPHOME_ALWAYS_INLINE |
| Get the integration where this component was declared as a LogString for logging. | |
| bool | should_warn_of_blocking (uint32_t blocking_time, uint32_t &threshold_ms_out) |
| Public Member Functions inherited from esphome::uart::UARTDevice | |
| UARTDevice ()=default | |
| UARTDevice (UARTComponent *parent) | |
| void | set_uart_parent (UARTComponent *parent) |
| void | write_byte (uint8_t data) |
| void | set_rx_full_threshold (size_t rx_full_threshold) |
| void | set_rx_full_threshold_ms (size_t time) |
| size_t | get_rx_full_threshold () |
| void | set_rx_timeout (size_t rx_timeout) |
| size_t | get_rx_timeout () |
| void | write_array (const uint8_t *data, size_t len) |
| void | write_array_progmem (const uint8_t *data, size_t len) |
| void | write_array (const std::vector< uint8_t > &data) |
| template<size_t N> | |
| void | write_array (const std::array< uint8_t, N > &data) |
| void | write_str (const char *str) |
| bool | read_byte (uint8_t *data) |
| bool | peek_byte (uint8_t *data) |
| bool | read_array (uint8_t *data, size_t len) |
| template<size_t N> | |
| optional< std::array< uint8_t, N > > | read_array () |
| size_t | available () |
| UARTFlushResult | flush () |
| int | read () |
| size_t | write (uint8_t data) |
| int | peek () |
| ESPDEPRECATED ("Use uart.final_validate_device_schema() in Python instead. Removed in 2027.3.0", "2026.9.0") void check_uart_settings(uint32_t baud_rate | |
| Check that the configuration of the UART bus matches the provided values and otherwise print a warning. | |
Static Public Member Functions | |
| static uint32_t | extract_field (uint32_t data, const RegisterField &field) |
Protected Member Functions | |
| virtual uint8_t | expected_version () const =0 |
| IC version reported in IOIN by the supported chip. | |
| virtual uint32_t * | shadow_register (uint8_t reg) |
| Return the cached value of a write-only register, or nullptr when the register is readable. | |
| virtual void | restore_registers () |
| Write the cached write-only registers and the last written configuration registers to the driver, at setup and after a driver reset. | |
| void | apply_config_ () |
| Write the settings from the configuration to the readable registers. | |
| virtual void | on_diag_without_error () |
| Called when DIAG rises without a driver error. | |
| bool | update_status_ () |
| Read GSTAT and DRV_STATUS and report changes. Returns false when the status could not be read. | |
| optional< uint8_t > | current_to_scale_ (float current) |
| float | full_scale_current_ () |
| int32_t | get_vactual_ () const |
| int32_t | speed_to_vactual_ (float speed) const |
| void | add_index_pulses_ () |
| void | loop_serial_ () |
| void | loop_step_dir_ () |
| Protected Member Functions inherited from esphome::stepper::Stepper | |
| void | calculate_speed_ (uint32_t now) |
| int32_t | should_step_ () |
| Protected Member Functions inherited from esphome::Component | |
| friend | void::setup () |
| friend | void::original_setup () |
| void | set_component_source_ (uint8_t index) |
| Set where this component was loaded from for some debug messages. | |
| virtual void | call_setup () |
| void | call_dump_config_ () |
| void | enable_loop_slow_path_ () |
| void | set_component_state_ (uint8_t state) |
| Helper to set component state (clears state bits and sets new state) | |
| bool | set_status_flag_ (uint8_t flag) |
| Helper to set a status LED flag on both this component and the app. | |
| bool | set_error_flag_ (const LogString *message) |
| Set the error flag and log it; true when it was not set before. | |
| void | set_interval (const char *name, uint32_t interval, std::function< void()> &&f) |
| Set an interval function with a const char* name. | |
| void | set_interval (uint32_t id, uint32_t interval, std::function< void()> &&f) |
| Set an interval function with a numeric ID (zero heap allocation). | |
| void | set_interval (InternalSchedulerID id, uint32_t interval, std::function< void()> &&f) |
| void | set_interval (uint32_t interval, std::function< void()> &&f) |
| bool | cancel_interval (const char *name) |
| Cancel an interval function. | |
| bool | cancel_interval (uint32_t id) |
| bool | cancel_interval (InternalSchedulerID id) |
| void | set_timeout (const char *name, uint32_t timeout, std::function< void()> &&f) |
| Set a timeout function with a const char* name. | |
| void | set_timeout (uint32_t id, uint32_t timeout, std::function< void()> &&f) |
| Set a timeout function with a numeric ID (zero heap allocation). | |
| void | set_timeout (InternalSchedulerID id, uint32_t timeout, std::function< void()> &&f) |
| void | set_timeout (uint32_t timeout, std::function< void()> &&f) |
| bool | cancel_timeout (const char *name) |
| Cancel a timeout function. | |
| bool | cancel_timeout (uint32_t id) |
| bool | cancel_timeout (InternalSchedulerID id) |
| void | defer (const char *name, std::function< void()> &&f) |
| Defer a callback to the next loop() call with a const char* name. | |
| void | defer (std::function< void()> &&f) |
| Defer a callback to the next loop() call. | |
| void | defer (uint32_t id, std::function< void()> &&f) |
| Defer a callback with a numeric ID (zero heap allocation) | |
| bool | cancel_defer (const char *name) |
| Cancel a defer callback using the specified name, name must not be empty. | |
| bool | cancel_defer (uint32_t id) |
| void | status_clear_warning_slow_path_ () |
| void | status_clear_error_slow_path_ () |
Protected Attributes | |
| GPIOPin * | enn_pin_ {nullptr} |
| GPIOPin * | step_pin_ {nullptr} |
| GPIOPin * | dir_pin_ {nullptr} |
| InternalGPIOPin * | index_pin_ {nullptr} |
| InternalGPIOPin * | diag_pin_ {nullptr} |
| LazyCallbackManager< void(DriverEvent, bool)> | status_callback_ |
| uint32_t | clock_frequency_ {12000000} |
| uint32_t | ihold_irun_ {0x00071703} |
| uint32_t | tpowerdown_ {0x14} |
| uint32_t | tpwmthrs_ {0} |
| uint32_t | vactual_reg_ {0} |
| std::array< uint32_t, RESTORED_REGISTERS.size()> | restored_values_ {} |
| float | rsense_ {NAN} |
| float | initial_run_current_ {NAN} |
| float | initial_hold_current_ {NAN} |
| IndexPulseStore | index_store_ {} |
| uint16_t | initial_microsteps_ {16} |
| uint16_t | status_ {0} |
| optional< bool > | vsense_ {} |
| optional< uint8_t > | ottrim_ {} |
| uint8_t | address_ {0} |
| uint8_t | toff_ {3} |
| uint8_t | version_ {0} |
| uint8_t | restored_written_ {0} |
| uint8_t | status_poll_skip_ {0} |
| int8_t | direction_ {0} |
| DiagPinStore | diag_store_ {} |
| bool | analog_current_scale_ {false} |
| bool | enabled_ {false} |
| bool | vsense_active_ {false} |
| bool | step_state_ {false} |
| bool | moving_ {false} |
| HighFrequencyLoopRequester | high_freq_ |
| Protected Attributes inherited from esphome::stepper::Stepper | |
| float | acceleration_ {1e6f} |
| float | deceleration_ {1e6f} |
| float | current_speed_ {0.0f} |
| float | max_speed_ {1e6f} |
| uint32_t | last_calculation_ {0} |
| uint32_t | last_step_ {0} |
| Protected Attributes inherited from esphome::Component | |
| uint8_t | component_source_index_ {0} |
| Index into component source PROGMEM lookup table (0 = not set) | |
| uint8_t | warn_if_blocking_over_ {WARN_IF_BLOCKING_OVER_CS} |
| Warn threshold in centiseconds (max 2550ms) | |
| uint8_t | component_state_ {0x00} |
| State of this component - each bit has a purpose: Bits 0-2: Component state (0x00=CONSTRUCTION, 0x01=SETUP, 0x02=LOOP, 0x03=FAILED, 0x04=LOOP_DONE) Bit 3: STATUS_LED_WARNING Bit 4: STATUS_LED_ERROR Bit 5: Has overridden loop() (set at registration time) Bits 6-7: Unused - reserved for future expansion. | |
| volatile bool | pending_enable_loop_ {false} |
| ISR-safe flag for enable_loop_soon_any_context. | |
| ComponentRuntimeStats | runtime_stats_ |
| Protected Attributes inherited from esphome::uart::UARTDevice | |
| UARTComponent * | parent_ {nullptr} |
Additional Inherited Members | |
| Data Fields inherited from esphome::stepper::Stepper | |
| int32_t | current_position {0} |
| int32_t | target_position {0} |
| Data Fields inherited from esphome::Component | |
| uint32_t | length = 5000) |
| Data Fields inherited from esphome::uart::UARTDevice | |
| uint8_t | stop_bits = 1 |
| uint8_t UARTParityOptions | parity = UART_CONFIG_PARITY_NONE |
| uint8_t UARTParityOptions uint8_t | data_bits = 8) |
Detailed Description
Base class for Trinamic stepper drivers that are configured over the single wire UART interface.
Member Function Documentation
◆ add_index_pulses_()
|
protected |
Definition at line 299 of file tmc22xx.cpp.
◆ add_on_status_callback()
|
inline |
◆ apply_config_()
|
protected |
Write the settings from the configuration to the readable registers.
Definition at line 157 of file tmc22xx.cpp.
◆ current_to_scale_()
|
protected |
Definition at line 408 of file tmc22xx.cpp.
◆ dump_config()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 229 of file tmc22xx.cpp.
◆ expected_version()
|
protectedpure virtual |
IC version reported in IOIN by the supported chip.
Implemented in esphome::tmc2209::TMC2209Stepper.
◆ extract_field()
|
static |
Definition at line 526 of file tmc22xx.cpp.
◆ full_scale_current_()
|
protected |
Definition at line 399 of file tmc22xx.cpp.
◆ get_microsteps()
| uint16_t esphome::tmc22xx::TMC22XXStepper::get_microsteps | ( | ) |
Definition at line 382 of file tmc22xx.cpp.
◆ get_setup_priority()
|
inlineoverridevirtual |
Reimplemented from esphome::Component.
◆ get_vactual_()
|
inlineprotected |
◆ is_enabled()
|
inline |
◆ is_unreachable()
|
inline |
◆ loop()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 264 of file tmc22xx.cpp.
◆ loop_serial_()
|
protected |
Definition at line 305 of file tmc22xx.cpp.
◆ loop_step_dir_()
|
protected |
Definition at line 326 of file tmc22xx.cpp.
◆ on_diag_without_error()
|
inlineprotectedvirtual |
Called when DIAG rises without a driver error.
Reimplemented in esphome::tmc2209::TMC2209Stepper.
◆ on_shutdown()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 339 of file tmc22xx.cpp.
◆ read_field()
| optional< uint32_t > esphome::tmc22xx::TMC22XXStepper::read_field | ( | const RegisterField & | field | ) |
Definition at line 519 of file tmc22xx.cpp.
◆ read_register()
| optional< uint32_t > esphome::tmc22xx::TMC22XXStepper::read_register | ( | uint8_t | reg | ) |
Definition at line 474 of file tmc22xx.cpp.
◆ restore_registers()
|
protectedvirtual |
Write the cached write-only registers and the last written configuration registers to the driver, at setup and after a driver reset.
Reimplemented in esphome::tmc2209::TMC2209Stepper.
Definition at line 146 of file tmc22xx.cpp.
◆ scale_to_current()
| float esphome::tmc22xx::TMC22XXStepper::scale_to_current | ( | uint8_t | scale | ) |
Convert a current scale (0-31) to A RMS, without analog current scale.
Definition at line 404 of file tmc22xx.cpp.
◆ set_address()
|
inline |
◆ set_analog_current_scale()
|
inline |
◆ set_clock_frequency()
|
inline |
◆ set_diag_pin()
|
inline |
◆ set_dir_pin()
|
inline |
◆ set_enabled()
| void esphome::tmc22xx::TMC22XXStepper::set_enabled | ( | bool | enabled | ) |
Enable or disable the motor outputs, using the ENN pin when configured and TOFF otherwise.
Definition at line 344 of file tmc22xx.cpp.
◆ set_enn_pin()
|
inline |
◆ set_hend()
|
inline |
◆ set_hold_current()
| void esphome::tmc22xx::TMC22XXStepper::set_hold_current | ( | float | current | ) |
Definition at line 394 of file tmc22xx.cpp.
◆ set_hstrt()
|
inline |
◆ set_ihold()
|
inline |
◆ set_iholddelay()
|
inline |
◆ set_index_pin()
|
inline |
◆ set_initial_hold_current()
|
inline |
◆ set_initial_microsteps()
|
inline |
◆ set_initial_run_current()
|
inline |
◆ set_interpolation()
|
inline |
◆ set_inverse_direction()
|
inline |
◆ set_irun()
|
inline |
◆ set_microsteps()
| void esphome::tmc22xx::TMC22XXStepper::set_microsteps | ( | uint16_t | microsteps | ) |
Definition at line 372 of file tmc22xx.cpp.
◆ set_ottrim()
|
inline |
◆ set_pwm_autograd()
|
inline |
◆ set_pwm_autoscale()
|
inline |
◆ set_pwm_freq()
|
inline |
◆ set_pwm_grad()
|
inline |
◆ set_pwm_lim()
|
inline |
◆ set_pwm_ofs()
|
inline |
◆ set_pwm_reg()
|
inline |
◆ set_rsense()
|
inline |
◆ set_run_current()
| void esphome::tmc22xx::TMC22XXStepper::set_run_current | ( | float | current | ) |
Set the motor run or hold current in A RMS.
Not supported with analog current scale, use set_irun() and set_ihold() instead.
Definition at line 389 of file tmc22xx.cpp.
◆ set_spreadcycle()
|
inline |
◆ set_standstill_mode()
|
inline |
◆ set_step_pin()
|
inline |
◆ set_tbl()
|
inline |
◆ set_toff()
| void esphome::tmc22xx::TMC22XXStepper::set_toff | ( | uint8_t | toff | ) |
Chopper off time (1-15). TOFF=0 is used to disable the outputs, so this is applied on the next enable.
Definition at line 365 of file tmc22xx.cpp.
◆ set_tpowerdown()
|
inline |
◆ set_tpwm_threshold()
|
inline |
◆ set_vsense()
|
inline |
◆ setup()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 93 of file tmc22xx.cpp.
◆ shadow_register()
|
protectedvirtual |
Return the cached value of a write-only register, or nullptr when the register is readable.
Reimplemented in esphome::tmc2209::TMC2209Stepper.
Definition at line 426 of file tmc22xx.cpp.
◆ speed_to_vactual_()
|
protected |
Definition at line 421 of file tmc22xx.cpp.
◆ update_status_()
|
protected |
Read GSTAT and DRV_STATUS and report changes. Returns false when the status could not be read.
Definition at line 186 of file tmc22xx.cpp.
◆ write_field()
| bool esphome::tmc22xx::TMC22XXStepper::write_field | ( | const RegisterField & | field, |
| uint32_t | value ) |
Definition at line 500 of file tmc22xx.cpp.
◆ write_register()
| bool esphome::tmc22xx::TMC22XXStepper::write_register | ( | uint8_t | reg, |
| uint32_t | value ) |
Definition at line 441 of file tmc22xx.cpp.
Field Documentation
◆ address_
|
protected |
◆ analog_current_scale_
|
protected |
◆ clock_frequency_
|
protected |
◆ diag_pin_
|
protected |
◆ diag_store_
|
protected |
◆ dir_pin_
|
protected |
◆ direction_
|
protected |
◆ enabled_
|
protected |
◆ enn_pin_
|
protected |
◆ high_freq_
|
protected |
◆ ihold_irun_
|
protected |
◆ index_pin_
|
protected |
◆ index_store_
|
protected |
◆ initial_hold_current_
|
protected |
◆ initial_microsteps_
|
protected |
◆ initial_run_current_
|
protected |
◆ moving_
|
protected |
◆ ottrim_
|
protected |
◆ restored_values_
|
protected |
◆ restored_written_
|
protected |
◆ rsense_
|
protected |
◆ status_
|
protected |
◆ status_callback_
|
protected |
◆ status_poll_skip_
|
protected |
◆ step_pin_
|
protected |
◆ step_state_
|
protected |
◆ toff_
|
protected |
◆ tpowerdown_
|
protected |
◆ tpwmthrs_
|
protected |
◆ vactual_reg_
|
protected |
◆ version_
|
protected |
◆ vsense_
|
protected |
◆ vsense_active_
|
protected |
The documentation for this class was generated from the following files:
- esphome/components/tmc22xx/tmc22xx.h
- esphome/components/tmc22xx/tmc22xx.cpp
Generated by
 1.12.0