Modbus controller class. More...
#include <modbus_controller.h>
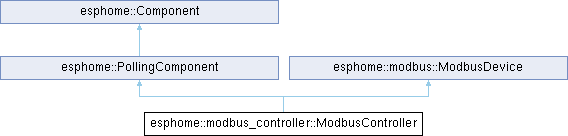
Public Member Functions | |
| ModbusController (modbus::ModbusClientHub *hub, uint8_t address) | |
| void | dump_config () override |
| void | setup () override |
| void | update () override |
| modbus::ModbusClientHub * | hub () const |
| The hub and modbus address this controller talks to. | |
| uint8_t | device_address () const |
| ESPDEPRECATED ("Use the entity write helpers or the modbus_client actions instead. Removed in 2027.3.0", "2026.9.0") void queue_command(ModbusCommandItem command) | |
| Queues a one-shot modbus command (writes, custom commands); taken by value, so std::move to avoid a copy. | |
| ESPDEPRECATED ("Serves only ModbusCommandItem's own callbacks. Removed in 2027.3.0", "2026.9.0") void unqueue_command(const ModbusCommandItem *command) | |
| Flags a finished one-shot command for removal. | |
| void | add_sensor_item (SensorItem *item) |
| Registers a sensor with the controller. Called by esphomes code generator. | |
| ESPDEPRECATED ("Write acknowledgements are handled by the writing entity's own device. Removed in 2027.3.0", "2026.9.0") void on_write_register_response(EntityType register_type | |
| Handles a write command acknowledgement (used by write command on_data_func handlers). | |
| void | set_online (bool online, int function_code, int register_address) |
| Update the online/offline state after a response or a run of timeouts, firing the callbacks. | |
| void | command_sent (int function_code, int register_address) |
| Fire the on_command_sent trigger (called when a command's frame reaches the wire). | |
| void | increment_non_response_count () |
| A command timed out; bump the consecutive-timeout counter used by can_send()/offline detection. | |
| bool | can_send () |
| Whether more retries are allowed before the device is considered offline. | |
| void | set_offline_skip_updates (uint16_t offline_skip_updates) |
| called by esphome generated code to set the offline_skip_updates | |
| bool | get_module_offline () |
| get if the module is offline, didn't respond the last command | |
| template<typename F > | |
| void | add_on_command_sent_callback (F &&callback) |
| Set callback for commands. | |
| template<typename F > | |
| void | add_on_online_callback (F &&callback) |
| Set callback for online changes. | |
| template<typename F > | |
| void | add_on_offline_callback (F &&callback) |
| Set callback for offline changes. | |
| void | set_max_cmd_retries (uint8_t max_cmd_retries) |
| called by esphome generated code to set the max_cmd_retries. | |
| uint8_t | get_max_cmd_retries () |
| get how many times a command will be (re)sent if no response is received | |
| void | set_read_options (modbus::CommandOptions options) |
| called by esphome generated code with the read-side command options applied to every poll | |
| const modbus::CommandOptions & | read_options () const |
| the read-side command options applied to every poll | |
 Public Member Functions inherited from esphome::PollingComponent | |
| PollingComponent () | |
| PollingComponent (uint32_t update_interval) | |
| Initialize this polling component with the given update interval in ms. | |
| void | set_update_interval (uint32_t update_interval) |
| Manually set the update interval in ms for this polling object. | |
| void | call_setup () override |
| virtual uint32_t | get_update_interval () const |
| Get the update interval in ms of this sensor. | |
| void | start_poller () |
| void | stop_poller () |
| Public Member Functions inherited from esphome::Component | |
| virtual void | loop () |
| This method will be called repeatedly. | |
| virtual float | get_setup_priority () const |
| priority of setup(). | |
| float | get_actual_setup_priority () const |
| void | set_setup_priority (float priority) |
| void | call () |
| virtual void | on_shutdown () |
| virtual void | on_safe_shutdown () |
| virtual bool | teardown () |
| Called during teardown to allow component to gracefully finish operations. | |
| virtual void | on_powerdown () |
| Called after teardown is complete to power down hardware. | |
| uint8_t | get_component_state () const |
| void | reset_to_construction_state () |
| Reset this component back to the construction state to allow setup to run again. | |
| bool | is_in_loop_state () const |
| Check if this component has completed setup and is in the loop state. | |
| bool | is_idle () const |
| Check if this component is idle. | |
| void | mark_failed () |
| Mark this component as failed. | |
| void | mark_failed (const LogString *message) |
| void | disable_loop () |
| Disable this component's loop. | |
| void | enable_loop () |
| Enable this component's loop. | |
| void | enable_loop_soon_any_context () |
| Thread and ISR-safe version of enable_loop() that can be called from any context. | |
| bool | is_failed () const |
| bool | is_ready () const |
| virtual bool | can_proceed () |
| bool | status_has_warning () const |
| bool | status_has_error () const |
| void | status_set_warning () |
| void | status_set_warning (const char *message) |
| void | status_set_warning (const LogString *message) |
| bool | status_comm_result (bool ok) |
Clears the warning when ok, else sets it with message (default "Communication failed"); returns ok. | |
| bool | status_comm_result (bool ok, const LogString *message) |
| void | status_set_error () |
| void | status_set_error (const LogString *message) |
| void | status_clear_warning () |
| void | status_clear_error () |
| ESPDEPRECATED ("Use status_momentary_warning() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_warning(const char *name | |
| void | status_momentary_warning (uint32_t length=5000) |
Set warning status flag and clear it after length ms. | |
| void | status_momentary_warning (const LogString *message, uint32_t length=5000) |
| ESPDEPRECATED ("Use status_momentary_error() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_error(const char *name | |
| void | status_momentary_error (uint32_t length=5000) |
Set error status flag and clear it after length ms. | |
| void | status_momentary_error (const LogString *message, uint32_t length=5000) |
| bool | has_overridden_loop () const |
| const LogString * | get_component_log_str () const ESPHOME_ALWAYS_INLINE |
| Get the integration where this component was declared as a LogString for logging. | |
| bool | should_warn_of_blocking (uint32_t blocking_time, uint32_t &threshold_ms_out) |
Data Fields | |
| uint16_t | start_address |
| uint16_t std::span< const uint8_t > | data |
| Data Fields inherited from esphome::Component | |
| uint32_t | length = 5000) |
Protected Member Functions | |
| void | create_polling_commands_ () |
| Group the registered sensors into contiguous ranges and create one PollingDevice per range. | |
| void | sweep_completed_one_shots_ () |
| Erases one-shot commands flagged by unqueue_command(). | |
| Protected Member Functions inherited from esphome::Component | |
| friend | void::setup () |
| friend | void::original_setup () |
| void | set_component_source_ (uint8_t index) |
| Set where this component was loaded from for some debug messages. | |
| void | call_dump_config_ () |
| void | enable_loop_slow_path_ () |
| void | set_component_state_ (uint8_t state) |
| Helper to set component state (clears state bits and sets new state) | |
| bool | set_status_flag_ (uint8_t flag) |
| Helper to set a status LED flag on both this component and the app. | |
| bool | set_error_flag_ (const LogString *message) |
| Set the error flag and log it; true when it was not set before. | |
| void | set_interval (const char *name, uint32_t interval, std::function< void()> &&f) |
| Set an interval function with a const char* name. | |
| void | set_interval (uint32_t id, uint32_t interval, std::function< void()> &&f) |
| Set an interval function with a numeric ID (zero heap allocation). | |
| void | set_interval (InternalSchedulerID id, uint32_t interval, std::function< void()> &&f) |
| void | set_interval (uint32_t interval, std::function< void()> &&f) |
| bool | cancel_interval (const char *name) |
| Cancel an interval function. | |
| bool | cancel_interval (uint32_t id) |
| bool | cancel_interval (InternalSchedulerID id) |
| void | set_timeout (const char *name, uint32_t timeout, std::function< void()> &&f) |
| Set a timeout function with a const char* name. | |
| void | set_timeout (uint32_t id, uint32_t timeout, std::function< void()> &&f) |
| Set a timeout function with a numeric ID (zero heap allocation). | |
| void | set_timeout (InternalSchedulerID id, uint32_t timeout, std::function< void()> &&f) |
| void | set_timeout (uint32_t timeout, std::function< void()> &&f) |
| bool | cancel_timeout (const char *name) |
| Cancel a timeout function. | |
| bool | cancel_timeout (uint32_t id) |
| bool | cancel_timeout (InternalSchedulerID id) |
| void | defer (const char *name, std::function< void()> &&f) |
| Defer a callback to the next loop() call with a const char* name. | |
| void | defer (std::function< void()> &&f) |
| Defer a callback to the next loop() call. | |
| void | defer (uint32_t id, std::function< void()> &&f) |
| Defer a callback with a numeric ID (zero heap allocation) | |
| bool | cancel_defer (const char *name) |
| Cancel a defer callback using the specified name, name must not be empty. | |
| bool | cancel_defer (uint32_t id) |
| void | status_clear_warning_slow_path_ () |
| void | status_clear_error_slow_path_ () |
Protected Attributes | |
| modbus::ModbusClientHub * | hub_ {nullptr} |
| The hub this controller's commands/entities send through, and the modbus address they target. | |
| uint8_t | address_ {0} |
| SensorSet | sensorset_ |
| Collection of all sensors for this component. | |
| FixedVector< PollingDevice > | polling_devices_ |
| One persistent PollingDevice per register range. | |
| std::list< std::unique_ptr< ModbusCommandItem > > | one_shot_command_items_ |
| Dynamically queued one-shot commands (writes, custom commands). | |
| bool | module_offline_ {false} |
| if module didn't respond the last command | |
| uint16_t | module_offline_at_ {0} |
| update_counter_ value at which the module went offline (for offline_skip_updates timing) | |
| uint16_t | update_counter_ {0} |
| counts update() cycles; drives the offline-retry cadence | |
| uint8_t | cmd_non_responses_ {0} |
| consecutive non-responses; drives can_send() and offline detection | |
| uint16_t | offline_skip_updates_ {0} |
| how many updates to skip if module is offline | |
| uint8_t | max_cmd_retries_ {4} |
| How many times we will retry a command if we get no response. | |
| modbus::CommandOptions | read_options_ {} |
| read-side command options applied to every poll | |
| CallbackManager< void(int, int)> | command_sent_callback_ {} |
| Command sent callback. | |
| CallbackManager< void(int, int)> | online_callback_ {} |
| Server online callback. | |
| CallbackManager< void(int, int)> | offline_callback_ {} |
| Server offline callback. | |
| Protected Attributes inherited from esphome::PollingComponent | |
| uint32_t | update_interval_ |
| Protected Attributes inherited from esphome::Component | |
| uint8_t | component_source_index_ {0} |
| Index into component source PROGMEM lookup table (0 = not set) | |
| uint8_t | warn_if_blocking_over_ {WARN_IF_BLOCKING_OVER_CS} |
| Warn threshold in centiseconds (max 2550ms) | |
| uint8_t | component_state_ {0x00} |
| State of this component - each bit has a purpose: Bits 0-2: Component state (0x00=CONSTRUCTION, 0x01=SETUP, 0x02=LOOP, 0x03=FAILED, 0x04=LOOP_DONE) Bit 3: STATUS_LED_WARNING Bit 4: STATUS_LED_ERROR Bit 5: Has overridden loop() (set at registration time) Bits 6-7: Unused - reserved for future expansion. | |
| volatile bool | pending_enable_loop_ {false} |
| ISR-safe flag for enable_loop_soon_any_context. | |
| ComponentRuntimeStats | runtime_stats_ |
Detailed Description
Modbus controller class.
Each instance handles the modbus commuinication for all sensors with the same modbus address
all sensor items (sensors, switches, binarysensor ...) are parsed in modbus address ranges. when esphome calls ModbusController::Update the commands for each range are created and sent Responses for the commands are dispatched to the modbus sensor items.
Definition at line 496 of file modbus_controller.h.
Constructor & Destructor Documentation
◆ ModbusController()
|
inline |
Definition at line 500 of file modbus_controller.h.
Member Function Documentation
◆ add_on_command_sent_callback()
|
inline |
Set callback for commands.
Definition at line 548 of file modbus_controller.h.
◆ add_on_offline_callback()
|
inline |
Set callback for offline changes.
Definition at line 556 of file modbus_controller.h.
◆ add_on_online_callback()
|
inline |
Set callback for online changes.
Definition at line 552 of file modbus_controller.h.
◆ add_sensor_item()
|
inline |
Registers a sensor with the controller. Called by esphomes code generator.
Definition at line 526 of file modbus_controller.h.
◆ can_send()
|
inline |
Whether more retries are allowed before the device is considered offline.
Deliberately pooled per device, not per command: online/offline is a property of the physical device.
Definition at line 542 of file modbus_controller.h.
◆ command_sent()
|
inline |
Fire the on_command_sent trigger (called when a command's frame reaches the wire).
Definition at line 535 of file modbus_controller.h.
◆ create_polling_commands_()
|
protected |
Group the registered sensors into contiguous ranges and create one PollingDevice per range.
Definition at line 500 of file modbus_controller.cpp.
◆ device_address()
|
inline |
Definition at line 511 of file modbus_controller.h.
◆ dump_config()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 533 of file modbus_controller.cpp.
◆ ESPDEPRECATED() [1/3]
| esphome::modbus_controller::ModbusController::ESPDEPRECATED | ( | "Serves only ModbusCommandItem's own callbacks. Removed in 2027.3.0" | , |
| "2026.9.0" | ) const |
Flags a finished one-shot command for removal.
Called by the command as the last action of its own callback, so the item is not destroyed here (send() and the hub still touch it) but swept later. Remove with ModbusCommandItem before 2027.3.0.
◆ ESPDEPRECATED() [2/3]
| esphome::modbus_controller::ModbusController::ESPDEPRECATED | ( | "Use the entity write helpers or the modbus_client actions instead. Removed in 2027.3.0" | , |
| "2026.9.0" | ) |
Queues a one-shot modbus command (writes, custom commands); taken by value, so std::move to avoid a copy.
Remove with ModbusCommandItem before 2027.3.0.
◆ ESPDEPRECATED() [3/3]
| esphome::modbus_controller::ModbusController::ESPDEPRECATED | ( | "Write acknowledgements are handled by the writing entity's own device. Removed in 2027.3.0" | , |
| "2026.9.0" | ) |
Handles a write command acknowledgement (used by write command on_data_func handlers).
Remove with ModbusCommandItem before 2027.3.0.
◆ get_max_cmd_retries()
|
inline |
get how many times a command will be (re)sent if no response is received
Definition at line 562 of file modbus_controller.h.
◆ get_module_offline()
|
inline |
get if the module is offline, didn't respond the last command
Definition at line 546 of file modbus_controller.h.
◆ hub()
|
inline |
The hub and modbus address this controller talks to.
Used to build commands/entities that send as their own device.
Definition at line 510 of file modbus_controller.h.
◆ increment_non_response_count()
|
inline |
A command timed out; bump the consecutive-timeout counter used by can_send()/offline detection.
Definition at line 539 of file modbus_controller.h.
◆ read_options()
|
inline |
the read-side command options applied to every poll
Definition at line 566 of file modbus_controller.h.
◆ set_max_cmd_retries()
|
inline |
called by esphome generated code to set the max_cmd_retries.
Definition at line 560 of file modbus_controller.h.
◆ set_offline_skip_updates()
|
inline |
called by esphome generated code to set the offline_skip_updates
Definition at line 544 of file modbus_controller.h.
◆ set_online()
| void esphome::modbus_controller::ModbusController::set_online | ( | bool | online, |
| int | function_code, | ||
| int | register_address ) |
Update the online/offline state after a response or a run of timeouts, firing the callbacks.
Definition at line 262 of file modbus_controller.cpp.
◆ set_read_options()
|
inline |
called by esphome generated code with the read-side command options applied to every poll
Definition at line 564 of file modbus_controller.h.
◆ setup()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 12 of file modbus_controller.cpp.
◆ sweep_completed_one_shots_()
|
protected |
Erases one-shot commands flagged by unqueue_command().
Safe even when reached from inside a hub callback (via an on_online/on_offline/on_command_sent automation that queues a command): the destructor detaches via clear_tx_queue_for_device(), which the hub allows from callbacks, and the item running its callback is not flagged until that callback returns.
Definition at line 314 of file modbus_controller.cpp.
◆ update()
|
overridevirtual |
Implements esphome::PollingComponent.
Definition at line 321 of file modbus_controller.cpp.
Field Documentation
◆ address_
|
protected |
Definition at line 573 of file modbus_controller.h.
◆ cmd_non_responses_
|
protected |
consecutive non-responses; drives can_send() and offline detection
Definition at line 597 of file modbus_controller.h.
◆ command_sent_callback_
|
protected |
Command sent callback.
Definition at line 605 of file modbus_controller.h.
◆ data
| uint16_t std::span<const uint8_t> esphome::modbus_controller::ModbusController::data |
Definition at line 531 of file modbus_controller.h.
◆ hub_
|
protected |
The hub this controller's commands/entities send through, and the modbus address they target.
Definition at line 572 of file modbus_controller.h.
◆ max_cmd_retries_
|
protected |
How many times we will retry a command if we get no response.
Definition at line 601 of file modbus_controller.h.
◆ module_offline_
|
protected |
if module didn't respond the last command
Definition at line 591 of file modbus_controller.h.
◆ module_offline_at_
|
protected |
update_counter_ value at which the module went offline (for offline_skip_updates timing)
Definition at line 593 of file modbus_controller.h.
◆ offline_callback_
|
protected |
Server offline callback.
Definition at line 609 of file modbus_controller.h.
◆ offline_skip_updates_
|
protected |
how many updates to skip if module is offline
Definition at line 599 of file modbus_controller.h.
◆ one_shot_command_items_
|
protected |
Dynamically queued one-shot commands (writes, custom commands).
std::list keeps stable addresses. Remove with ModbusCommandItem before 2027.3.0.
Definition at line 583 of file modbus_controller.h.
◆ online_callback_
|
protected |
Server online callback.
Definition at line 607 of file modbus_controller.h.
◆ polling_devices_
|
protected |
One persistent PollingDevice per register range.
Built once in setup() with the exact count (FixedVector never reallocates), so the hub's device pointers stay valid once polls start sending.
Definition at line 578 of file modbus_controller.h.
◆ read_options_
|
protected |
read-side command options applied to every poll
Definition at line 603 of file modbus_controller.h.
◆ sensorset_
|
protected |
Collection of all sensors for this component.
Definition at line 575 of file modbus_controller.h.
◆ start_address
| uint16_t esphome::modbus_controller::ModbusController::start_address |
Definition at line 531 of file modbus_controller.h.
◆ update_counter_
|
protected |
counts update() cycles; drives the offline-retry cadence
Definition at line 595 of file modbus_controller.h.
The documentation for this class was generated from the following files:
- esphome/components/modbus_controller/modbus_controller.h
- esphome/components/modbus_controller/modbus_controller.cpp
Generated by
 1.12.0