FUSB302B USB Type-C / Power Delivery sink controller. More...
#include <fusb302b.h>
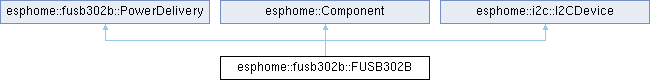
Public Member Functions | |
| FUSB302B (InternalGPIOPin *interrupt_pin) | |
| void | setup () override |
| void | loop () override |
| void | dump_config () override |
| void | on_shutdown () override |
| float | get_setup_priority () const override |
| void | request_voltage (int voltage) |
Negotiate a new contract with the highest source voltage that does not exceed voltage. | |
| template<typename F > | |
| void | add_on_state_callback (F &&callback) |
| Callbacks receive each new state in order, with the state before it. | |
| template<typename F > | |
| void | add_on_request_failed_callback (F &&callback) |
| Called when a voltage request was rejected, got no answer, or was dropped because the component failed. | |
| void | set_voltage_sensor (sensor::Sensor *sensor) |
| void | set_current_sensor (sensor::Sensor *sensor) |
| void | set_contract_text_sensor (text_sensor::TextSensor *sensor) |
 Public Member Functions inherited from esphome::fusb302b::PowerDelivery | |
| void | set_request_voltage (uint8_t voltage) |
| uint8_t | get_request_voltage () const |
| PdState | get_state () const |
| bool | is_connected () const |
| Public Member Functions inherited from esphome::Component | |
| float | get_actual_setup_priority () const |
| void | set_setup_priority (float priority) |
| void | call () |
| virtual void | on_safe_shutdown () |
| virtual bool | teardown () |
| Called during teardown to allow component to gracefully finish operations. | |
| virtual void | on_powerdown () |
| Called after teardown is complete to power down hardware. | |
| uint8_t | get_component_state () const |
| void | reset_to_construction_state () |
| Reset this component back to the construction state to allow setup to run again. | |
| bool | is_in_loop_state () const |
| Check if this component has completed setup and is in the loop state. | |
| bool | is_idle () const |
| Check if this component is idle. | |
| void | mark_failed () |
| Mark this component as failed. | |
| void | mark_failed (const LogString *message) |
| void | disable_loop () |
| Disable this component's loop. | |
| void | enable_loop () |
| Enable this component's loop. | |
| void | enable_loop_soon_any_context () |
| Thread and ISR-safe version of enable_loop() that can be called from any context. | |
| bool | is_failed () const |
| bool | is_ready () const |
| virtual bool | can_proceed () |
| bool | status_has_warning () const |
| bool | status_has_error () const |
| void | status_set_warning () |
| void | status_set_warning (const char *message) |
| void | status_set_warning (const LogString *message) |
| void | status_set_error () |
| void | status_set_error (const LogString *message) |
| void | status_clear_warning () |
| void | status_clear_error () |
| ESPDEPRECATED ("Use status_momentary_warning() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_warning(const char *name | |
| void | status_momentary_warning (uint32_t length=5000) |
Set warning status flag and clear it after length ms. | |
| void | status_momentary_warning (const LogString *message, uint32_t length=5000) |
| ESPDEPRECATED ("Use status_momentary_error() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_error(const char *name | |
| void | status_momentary_error (uint32_t length=5000) |
Set error status flag and clear it after length ms. | |
| void | status_momentary_error (const LogString *message, uint32_t length=5000) |
| bool | has_overridden_loop () const |
| const LogString * | get_component_log_str () const ESPHOME_ALWAYS_INLINE |
| Get the integration where this component was declared as a LogString for logging. | |
| bool | should_warn_of_blocking (uint32_t blocking_time, uint32_t &threshold_ms_out) |
| Public Member Functions inherited from esphome::i2c::I2CDevice | |
| I2CDevice ()=default | |
| we use the C++ default constructor | |
| void | set_i2c_address (uint8_t address) |
| We store the address of the device on the bus. | |
| uint8_t | get_i2c_address () const |
| Returns the I2C address of the object. | |
| void | set_i2c_bus (I2CBus *bus) |
| we store the pointer to the I2CBus to use | |
| I2CRegister | reg (uint8_t a_register) |
| calls the I2CRegister constructor | |
| I2CRegister16 | reg16 (uint16_t a_register) |
| calls the I2CRegister16 constructor | |
| ErrorCode | read (uint8_t *data, size_t len) const |
| reads an array of bytes from the device using an I2CBus | |
| ErrorCode | read_register (uint8_t a_register, uint8_t *data, size_t len) |
| reads an array of bytes from a specific register in the I²C device | |
| ErrorCode | read_register16 (uint16_t a_register, uint8_t *data, size_t len) |
| reads an array of bytes from a specific register in the I²C device | |
| ErrorCode | write (const uint8_t *data, size_t len) const |
| writes an array of bytes to a device using an I2CBus | |
| ErrorCode | write_read (const uint8_t *write_data, size_t write_len, uint8_t *read_data, size_t read_len) const |
| writes an array of bytes to a device, then reads an array, as a single transaction | |
| ErrorCode | write_register (uint8_t a_register, const uint8_t *data, size_t len) const |
| writes an array of bytes to a specific register in the I²C device | |
| ErrorCode | write_register16 (uint16_t a_register, const uint8_t *data, size_t len) const |
| write an array of bytes to a specific register in the I²C device | |
| bool | read_bytes (uint8_t a_register, uint8_t *data, uint8_t len) |
| Compat APIs All methods below have been added for compatibility reasons. | |
| bool | read_bytes_raw (uint8_t *data, uint8_t len) const |
| template<size_t N> | |
| optional< std::array< uint8_t, N > > | read_bytes (uint8_t a_register) |
| template<size_t N> | |
| optional< std::array< uint8_t, N > > | read_bytes_raw () |
| bool | read_bytes_16 (uint8_t a_register, uint16_t *data, uint8_t len) |
| bool | read_byte (uint8_t a_register, uint8_t *data) |
| optional< uint8_t > | read_byte (uint8_t a_register) |
| bool | read_byte_16 (uint8_t a_register, uint16_t *data) |
| bool | write_bytes (uint8_t a_register, const uint8_t *data, uint8_t len) const |
| bool | write_bytes (uint8_t a_register, const std::vector< uint8_t > &data) const |
| template<size_t N> | |
| bool | write_bytes (uint8_t a_register, const std::array< uint8_t, N > &data) |
| bool | write_bytes_16 (uint8_t a_register, const uint16_t *data, uint8_t len) const |
| bool | write_byte (uint8_t a_register, uint8_t data) const |
| bool | write_byte_16 (uint8_t a_register, uint16_t data) const |
Protected Types | |
| enum class | SourceCapStep : uint8_t { SOURCE_CAP_STEP_WAIT , SOURCE_CAP_STEP_GET_SENT , SOURCE_CAP_STEP_SOFT_RESET_SENT } |
Protected Member Functions | |
| bool | send_message (const PdMsg &msg) override |
| void | on_state_changed () override |
| void | on_soft_reset_received () override |
| void | on_source_caps_received () override |
| void | on_transition_timeout () override |
| void | on_request_failed () override |
| void | run_task_ () |
| bool | init_chip_ () |
| bool | reset_pd_ () |
| bool | enable_auto_crc_ () |
| void | handle_interrupt_ () |
| bool | read_message_ (PdMsg &msg, bool &is_sop) |
| void | try_attach_ () |
| bool | measure_cc_ (uint8_t meas_switch, uint8_t &level) |
| void | detach_ () |
| void | handle_hard_reset_ () |
| void | start_source_cap_wait_ (SourceCapStep step) |
| void | start_negotiation_ () |
| void | send_soft_reset_ () |
| void | source_caps_failed_ () |
| void | check_source_caps_ () |
| void | enter_error_ () |
| void | publish_contract_ (PackedContract contract) |
| void | publish_state_ (PdState state) |
| void | queue_event_ (uint8_t event) |
| Protected Member Functions inherited from esphome::fusb302b::PowerDelivery | |
| void | handle_message_ (const PdMsg &msg) |
| void | handle_transmit_failed_ () |
| Called by the PHY when the chip gave up on a message after its retries without receiving a GoodCRC. | |
| void | reset_protocol_ () |
| void | set_state_ (PdState state) |
| void | set_contract_ (const PdContract &contract) |
| void | clear_contract_ () |
| void | set_state_and_contract_ (PdState state, const PdContract &contract) |
| Stores both before calling on_state_changed() once, so the main loop never sees the new state with the old contract. | |
| void | set_ams_ (bool active) |
| bool | check_ams_ () |
| Returns true while an atomic message sequence is in progress. | |
| void | check_transition_timeout_ () |
| Falls back to default power when the source accepted a request but did not report the new supply ready in time. | |
| void | check_request_retry_ () |
| Sends the last request again once tSinkRequest has passed after the source answered Wait. | |
| PdMsg | make_control_msg_ (PdControlMsgType type) const |
| PdMsg | make_data_msg_ (PdDataMsgType type, const uint32_t *objects, uint8_t len) const |
| Protected Member Functions inherited from esphome::Component | |
| friend | void::setup () |
| friend | void::original_setup () |
| void | set_component_source_ (uint8_t index) |
| Set where this component was loaded from for some debug messages. | |
| virtual void | call_setup () |
| void | call_dump_config_ () |
| void | enable_loop_slow_path_ () |
| void | set_component_state_ (uint8_t state) |
| Helper to set component state (clears state bits and sets new state) | |
| bool | set_status_flag_ (uint8_t flag) |
| Helper to set a status LED flag on both this component and the app. | |
| bool | set_error_flag_ (const LogString *message) |
| Set the error flag and log it; true when it was not set before. | |
| void | set_interval (const char *name, uint32_t interval, std::function< void()> &&f) |
| Set an interval function with a const char* name. | |
| void | set_interval (uint32_t id, uint32_t interval, std::function< void()> &&f) |
| Set an interval function with a numeric ID (zero heap allocation). | |
| void | set_interval (InternalSchedulerID id, uint32_t interval, std::function< void()> &&f) |
| void | set_interval (uint32_t interval, std::function< void()> &&f) |
| bool | cancel_interval (const char *name) |
| Cancel an interval function. | |
| bool | cancel_interval (uint32_t id) |
| bool | cancel_interval (InternalSchedulerID id) |
| void | set_timeout (const char *name, uint32_t timeout, std::function< void()> &&f) |
| Set a timeout function with a const char* name. | |
| void | set_timeout (uint32_t id, uint32_t timeout, std::function< void()> &&f) |
| Set a timeout function with a numeric ID (zero heap allocation). | |
| void | set_timeout (InternalSchedulerID id, uint32_t timeout, std::function< void()> &&f) |
| void | set_timeout (uint32_t timeout, std::function< void()> &&f) |
| bool | cancel_timeout (const char *name) |
| Cancel a timeout function. | |
| bool | cancel_timeout (uint32_t id) |
| bool | cancel_timeout (InternalSchedulerID id) |
| void | defer (const char *name, std::function< void()> &&f) |
| Defer a callback to the next loop() call with a const char* name. | |
| void | defer (std::function< void()> &&f) |
| Defer a callback to the next loop() call. | |
| void | defer (uint32_t id, std::function< void()> &&f) |
| Defer a callback with a numeric ID (zero heap allocation) | |
| bool | cancel_defer (const char *name) |
| Cancel a defer callback using the specified name, name must not be empty. | |
| bool | cancel_defer (uint32_t id) |
| void | status_clear_warning_slow_path_ () |
| void | status_clear_error_slow_path_ () |
Static Protected Member Functions | |
| static void | gpio_intr (FUSB302B *arg) |
| static void | task_func (void *arg) |
Protected Attributes | |
| InternalGPIOPin * | interrupt_pin_ |
| StaticTask | task_ |
| uint32_t | source_cap_step_start_ {0} |
| SourceCapStep | source_cap_step_ {SourceCapStep::SOURCE_CAP_STEP_WAIT} |
| bool | attached_ {false} |
| bool | waiting_for_source_caps_ {false} |
| bool | cc_ambiguous_logged_ {false} |
| bool | request_pending_ {false} |
| PdState | queued_state_ {PdState::PD_STATE_DISCONNECTED} |
| std::array< uint8_t, EVENT_QUEUE_SIZE > | event_queue_ {} |
| std::atomic< uint8_t > | event_queue_head_ {0} |
| std::atomic< uint8_t > | event_queue_tail_ {0} |
| std::atomic< bool > | event_queue_overflow_ {false} |
| std::atomic< uint8_t > | dropped_request_failures_ {0} |
| PdState | published_state_ {PdState::PD_STATE_DISCONNECTED} |
| uint32_t | published_contract_ {UINT32_MAX} |
| LazyCallbackManager< void(PdState, PdState)> | state_callback_ |
| LazyCallbackManager< void()> | request_failed_callback_ |
| sensor::Sensor * | voltage_sensor_ {nullptr} |
| sensor::Sensor * | current_sensor_ {nullptr} |
| text_sensor::TextSensor * | contract_text_sensor_ {nullptr} |
| Protected Attributes inherited from esphome::fusb302b::PowerDelivery | |
| std::atomic< PdState > | state_ {PdState::PD_STATE_DISCONNECTED} |
| std::atomic< uint32_t > | contract_ {0} |
| std::atomic< uint8_t > | request_voltage_ {5} |
| uint32_t | ams_start_ {0} |
| uint32_t | wait_received_ms_ {0} |
| bool | retry_request_pending_ {false} |
| Protected Attributes inherited from esphome::Component | |
| uint8_t | component_source_index_ {0} |
| Index into component source PROGMEM lookup table (0 = not set) | |
| uint8_t | warn_if_blocking_over_ {WARN_IF_BLOCKING_OVER_CS} |
| Warn threshold in centiseconds (max 2550ms) | |
| uint8_t | component_state_ {0x00} |
| State of this component - each bit has a purpose: Bits 0-2: Component state (0x00=CONSTRUCTION, 0x01=SETUP, 0x02=LOOP, 0x03=FAILED, 0x04=LOOP_DONE) Bit 3: STATUS_LED_WARNING Bit 4: STATUS_LED_ERROR Bit 5: Has overridden loop() (set at registration time) Bits 6-7: Unused - reserved for future expansion. | |
| volatile bool | pending_enable_loop_ {false} |
| ISR-safe flag for enable_loop_soon_any_context. | |
| ComponentRuntimeStats | runtime_stats_ |
| Protected Attributes inherited from esphome::i2c::I2CDevice | |
| uint8_t | address_ {0x00} |
| store the address of the device on the bus | |
| I2CBus * | bus_ {nullptr} |
| pointer to I2CBus instance | |
Static Protected Attributes | |
| static constexpr uint8_t | EVENT_QUEUE_SIZE = 8 |
| static constexpr uint8_t | EVENT_REQUEST_FAILED = 0xFF |
Additional Inherited Members | |
| Data Fields inherited from esphome::Component | |
| uint32_t | length = 5000) |
Detailed Description
FUSB302B USB Type-C / Power Delivery sink controller.
A dedicated task owns all I2C traffic to the chip so that PD replies meet the protocol timing even while the main loop is busy. The main loop only publishes state changes.
Definition at line 30 of file fusb302b.h.
Member Enumeration Documentation
◆ SourceCapStep
|
strongprotected |
| Enumerator | |
|---|---|
| SOURCE_CAP_STEP_WAIT | |
| SOURCE_CAP_STEP_GET_SENT | |
| SOURCE_CAP_STEP_SOFT_RESET_SENT | |
Definition at line 63 of file fusb302b.h.
Constructor & Destructor Documentation
◆ FUSB302B()
|
inlineexplicit |
Definition at line 32 of file fusb302b.h.
Member Function Documentation
◆ add_on_request_failed_callback()
|
inline |
Called when a voltage request was rejected, got no answer, or was dropped because the component failed.
A contract already in place stays valid.
Definition at line 50 of file fusb302b.h.
◆ add_on_state_callback()
|
inline |
Callbacks receive each new state in order, with the state before it.
Definition at line 45 of file fusb302b.h.
◆ check_source_caps_()
|
protected |
Definition at line 548 of file fusb302b.cpp.
◆ detach_()
|
protected |
Definition at line 470 of file fusb302b.cpp.
◆ dump_config()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 170 of file fusb302b.cpp.
◆ enable_auto_crc_()
|
protected |
Definition at line 288 of file fusb302b.cpp.
◆ enter_error_()
|
protected |
Definition at line 493 of file fusb302b.cpp.
◆ get_setup_priority()
|
inlineoverridevirtual |
Reimplemented from esphome::Component.
Definition at line 38 of file fusb302b.h.
◆ gpio_intr()
|
staticprotected |
Definition at line 41 of file fusb302b.cpp.
◆ handle_hard_reset_()
|
protected |
Definition at line 480 of file fusb302b.cpp.
◆ handle_interrupt_()
|
protected |
Definition at line 294 of file fusb302b.cpp.
◆ init_chip_()
|
protected |
Definition at line 255 of file fusb302b.cpp.
◆ loop()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 105 of file fusb302b.cpp.
◆ measure_cc_()
|
protected |
Definition at line 394 of file fusb302b.cpp.
◆ on_request_failed()
|
overrideprotectedvirtual |
Implements esphome::fusb302b::PowerDelivery.
Definition at line 103 of file fusb302b.cpp.
◆ on_shutdown()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 186 of file fusb302b.cpp.
◆ on_soft_reset_received()
|
inlineoverrideprotectedvirtual |
Implements esphome::fusb302b::PowerDelivery.
Definition at line 74 of file fusb302b.h.
◆ on_source_caps_received()
|
inlineoverrideprotectedvirtual |
Implements esphome::fusb302b::PowerDelivery.
Definition at line 75 of file fusb302b.h.
◆ on_state_changed()
|
overrideprotectedvirtual |
Implements esphome::fusb302b::PowerDelivery.
Definition at line 92 of file fusb302b.cpp.
◆ on_transition_timeout()
|
inlineoverrideprotectedvirtual |
Implements esphome::fusb302b::PowerDelivery.
Definition at line 76 of file fusb302b.h.
◆ publish_contract_()
|
protected |
Definition at line 150 of file fusb302b.cpp.
◆ publish_state_()
|
protected |
Definition at line 142 of file fusb302b.cpp.
◆ queue_event_()
|
protected |
Definition at line 79 of file fusb302b.cpp.
◆ read_message_()
|
protected |
Definition at line 341 of file fusb302b.cpp.
◆ request_voltage()
| void esphome::fusb302b::FUSB302B::request_voltage | ( | int | voltage | ) |
Negotiate a new contract with the highest source voltage that does not exceed voltage.
Values outside 5-20 V are clamped with a warning.
Definition at line 193 of file fusb302b.cpp.
◆ reset_pd_()
|
protected |
Definition at line 281 of file fusb302b.cpp.
◆ run_task_()
|
protected |
Definition at line 210 of file fusb302b.cpp.
◆ send_message()
|
overrideprotectedvirtual |
Implements esphome::fusb302b::PowerDelivery.
Definition at line 360 of file fusb302b.cpp.
◆ send_soft_reset_()
|
protected |
Definition at line 516 of file fusb302b.cpp.
◆ set_contract_text_sensor()
|
inline |
Definition at line 59 of file fusb302b.h.
◆ set_current_sensor()
|
inline |
Definition at line 56 of file fusb302b.h.
◆ set_voltage_sensor()
|
inline |
Definition at line 55 of file fusb302b.h.
◆ setup()
|
overridevirtual |
Reimplemented from esphome::Component.
Definition at line 52 of file fusb302b.cpp.
◆ source_caps_failed_()
|
protected |
Definition at line 530 of file fusb302b.cpp.
◆ start_negotiation_()
|
protected |
Definition at line 506 of file fusb302b.cpp.
◆ start_source_cap_wait_()
|
protected |
Definition at line 542 of file fusb302b.cpp.
◆ task_func()
|
staticprotected |
Definition at line 50 of file fusb302b.cpp.
◆ try_attach_()
|
protected |
Definition at line 413 of file fusb302b.cpp.
Field Documentation
◆ attached_
|
protected |
Definition at line 107 of file fusb302b.h.
◆ cc_ambiguous_logged_
|
protected |
Definition at line 109 of file fusb302b.h.
◆ contract_text_sensor_
|
protected |
Definition at line 137 of file fusb302b.h.
◆ current_sensor_
|
protected |
Definition at line 134 of file fusb302b.h.
◆ dropped_request_failures_
|
protected |
Definition at line 124 of file fusb302b.h.
◆ event_queue_
|
protected |
Definition at line 119 of file fusb302b.h.
◆ event_queue_head_
|
protected |
Definition at line 120 of file fusb302b.h.
◆ event_queue_overflow_
|
protected |
Definition at line 122 of file fusb302b.h.
◆ EVENT_QUEUE_SIZE
|
staticconstexprprotected |
Definition at line 117 of file fusb302b.h.
◆ event_queue_tail_
|
protected |
Definition at line 121 of file fusb302b.h.
◆ EVENT_REQUEST_FAILED
|
staticconstexprprotected |
Definition at line 118 of file fusb302b.h.
◆ interrupt_pin_
|
protected |
Definition at line 101 of file fusb302b.h.
◆ published_contract_
|
protected |
Definition at line 128 of file fusb302b.h.
◆ published_state_
|
protected |
Definition at line 127 of file fusb302b.h.
◆ queued_state_
|
protected |
Definition at line 112 of file fusb302b.h.
◆ request_failed_callback_
|
protected |
Definition at line 131 of file fusb302b.h.
◆ request_pending_
|
protected |
Definition at line 110 of file fusb302b.h.
◆ source_cap_step_
|
protected |
Definition at line 106 of file fusb302b.h.
◆ source_cap_step_start_
|
protected |
Definition at line 105 of file fusb302b.h.
◆ state_callback_
|
protected |
Definition at line 130 of file fusb302b.h.
◆ task_
|
protected |
Definition at line 102 of file fusb302b.h.
◆ voltage_sensor_
|
protected |
Definition at line 133 of file fusb302b.h.
◆ waiting_for_source_caps_
|
protected |
Definition at line 108 of file fusb302b.h.
The documentation for this class was generated from the following files:
- esphome/components/fusb302b/fusb302b.h
- esphome/components/fusb302b/fusb302b.cpp
Generated by
 1.12.0