DFRobot "Factory Calibrated Electrochemical Gas Sensor" series (SEN0465 to SEN0476). More...
#include <dfrobot_sen0465_base.h>
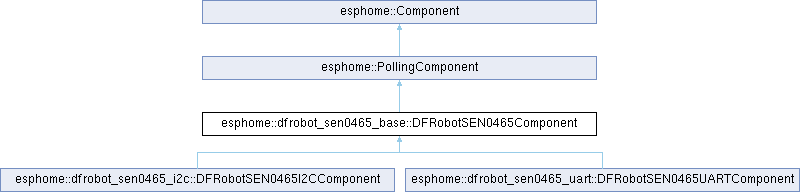
Data Structures | |
| struct | CompensationRange |
Protected Member Functions | |
| virtual bool | write_frame (const uint8_t *frame)=0 |
| Sends one complete request frame. | |
| virtual void | read_response ()=0 |
| Waits for the answer to a request, then calls either handle_response_() or handle_no_response_(), once. | |
| void | handle_response_ (const uint8_t *frame) |
| void | handle_no_response_ () |
| void | fail_reading_ () |
| Publish unknown on both sensors and set the warning when a reading cannot be used. | |
| bool | send_step_request_ () |
| Sends the request of the current step. | |
| void | retry_step_request_ () |
| Sends the request again from a scheduled callback; a failed write counts as a failed attempt. | |
| void | step_failed_ (const LogString *reason) |
| void | next_step_ () |
| void | handle_data_ (const uint8_t *frame) |
| bool | send_command_ (uint8_t command, uint8_t arg0=0, uint8_t arg1=0, uint8_t arg2=0, uint8_t arg3=0) |
| Sends a request and waits for its answer; returns false when the request could not be sent. | |
| float | compensate_ (float concentration, float temperature) const |
| Returns NAN when the temperature is outside every range. | |
 Protected Member Functions inherited from esphome::Component | |
| friend | void::setup () |
| friend | void::original_setup () |
| void | set_component_source_ (uint8_t index) |
| Set where this component was loaded from for some debug messages. | |
| void | call_dump_config_ () |
| void | enable_loop_slow_path_ () |
| void | set_component_state_ (uint8_t state) |
| Helper to set component state (clears state bits and sets new state) | |
| bool | set_status_flag_ (uint8_t flag) |
| Helper to set a status LED flag on both this component and the app. | |
| bool | set_error_flag_ (const LogString *message) |
| Set the error flag and log it; true when it was not set before. | |
| void | set_interval (const char *name, uint32_t interval, std::function< void()> &&f) |
| Set an interval function with a const char* name. | |
| void | set_interval (uint32_t id, uint32_t interval, std::function< void()> &&f) |
| Set an interval function with a numeric ID (zero heap allocation). | |
| void | set_interval (InternalSchedulerID id, uint32_t interval, std::function< void()> &&f) |
| void | set_interval (uint32_t interval, std::function< void()> &&f) |
| bool | cancel_interval (const char *name) |
| Cancel an interval function. | |
| bool | cancel_interval (uint32_t id) |
| bool | cancel_interval (InternalSchedulerID id) |
| void | set_timeout (const char *name, uint32_t timeout, std::function< void()> &&f) |
| Set a timeout function with a const char* name. | |
| void | set_timeout (uint32_t id, uint32_t timeout, std::function< void()> &&f) |
| Set a timeout function with a numeric ID (zero heap allocation). | |
| void | set_timeout (InternalSchedulerID id, uint32_t timeout, std::function< void()> &&f) |
| void | set_timeout (uint32_t timeout, std::function< void()> &&f) |
| bool | cancel_timeout (const char *name) |
| Cancel a timeout function. | |
| bool | cancel_timeout (uint32_t id) |
| bool | cancel_timeout (InternalSchedulerID id) |
| void | defer (const char *name, std::function< void()> &&f) |
| Defer a callback to the next loop() call with a const char* name. | |
| void | defer (std::function< void()> &&f) |
| Defer a callback to the next loop() call. | |
| void | defer (uint32_t id, std::function< void()> &&f) |
| Defer a callback with a numeric ID (zero heap allocation) | |
| bool | cancel_defer (const char *name) |
| Cancel a defer callback using the specified name, name must not be empty. | |
| bool | cancel_defer (uint32_t id) |
| void | status_clear_warning_slow_path_ () |
| void | status_clear_error_slow_path_ () |
Protected Attributes | |
| const char * | gas_name_ |
| uint16_t | alarm_threshold_ {0} |
| uint8_t | gas_type_ |
| AlarmType | alarm_type_ {AlarmType::ALARM_TYPE_OFF} |
| uint8_t | alarm_decimals_ {0} |
| SetupStep | step_ {SetupStep::SETUP_STEP_ACQUIRE_MODE} |
| uint8_t | attempts_ {0} |
| uint8_t | pending_command_ {0} |
| Command whose answer is awaited, 0 when no request is outstanding. | |
| bool | setup_incomplete_ {false} |
| A setup step gave up, so the alarm or the mode may not be what was configured. | |
| StaticVector< CompensationRange, DFROBOT_SEN0465_COMPENSATION_RANGES > | compensation_ |
| Protected Attributes inherited from esphome::PollingComponent | |
| uint32_t | update_interval_ |
| Protected Attributes inherited from esphome::Component | |
| uint8_t | component_source_index_ {0} |
| Index into component source PROGMEM lookup table (0 = not set) | |
| uint8_t | warn_if_blocking_over_ {WARN_IF_BLOCKING_OVER_CS} |
| Warn threshold in centiseconds (max 2550ms) | |
| uint8_t | component_state_ {0x00} |
| State of this component - each bit has a purpose: Bits 0-2: Component state (0x00=CONSTRUCTION, 0x01=SETUP, 0x02=LOOP, 0x03=FAILED, 0x04=LOOP_DONE) Bit 3: STATUS_LED_WARNING Bit 4: STATUS_LED_ERROR Bit 5: Has overridden loop() (set at registration time) Bits 6-7: Unused - reserved for future expansion. | |
| volatile bool | pending_enable_loop_ {false} |
| ISR-safe flag for enable_loop_soon_any_context. | |
| ComponentRuntimeStats | runtime_stats_ |
Additional Inherited Members | |
| Public Member Functions inherited from esphome::PollingComponent | |
| PollingComponent () | |
| PollingComponent (uint32_t update_interval) | |
| Initialize this polling component with the given update interval in ms. | |
| void | set_update_interval (uint32_t update_interval) |
| Manually set the update interval in ms for this polling object. | |
| void | call_setup () override |
| virtual uint32_t | get_update_interval () const |
| Get the update interval in ms of this sensor. | |
| void | start_poller () |
| void | stop_poller () |
| Public Member Functions inherited from esphome::Component | |
| virtual void | loop () |
| This method will be called repeatedly. | |
| virtual float | get_setup_priority () const |
| priority of setup(). | |
| float | get_actual_setup_priority () const |
| void | set_setup_priority (float priority) |
| void | call () |
| virtual void | on_shutdown () |
| virtual void | on_safe_shutdown () |
| virtual bool | teardown () |
| Called during teardown to allow component to gracefully finish operations. | |
| virtual void | on_powerdown () |
| Called after teardown is complete to power down hardware. | |
| uint8_t | get_component_state () const |
| void | reset_to_construction_state () |
| Reset this component back to the construction state to allow setup to run again. | |
| bool | is_in_loop_state () const |
| Check if this component has completed setup and is in the loop state. | |
| bool | is_idle () const |
| Check if this component is idle. | |
| void | mark_failed () |
| Mark this component as failed. | |
| void | mark_failed (const LogString *message) |
| void | disable_loop () |
| Disable this component's loop. | |
| void | enable_loop () |
| Enable this component's loop. | |
| void | enable_loop_soon_any_context () |
| Thread and ISR-safe version of enable_loop() that can be called from any context. | |
| bool | is_failed () const |
| bool | is_ready () const |
| virtual bool | can_proceed () |
| bool | status_has_warning () const |
| bool | status_has_error () const |
| void | status_set_warning () |
| void | status_set_warning (const char *message) |
| void | status_set_warning (const LogString *message) |
| bool | status_comm_result (bool ok) |
Clears the warning when ok, else sets it with message (default "Communication failed"); returns ok. | |
| bool | status_comm_result (bool ok, const LogString *message) |
| void | status_set_error () |
| void | status_set_error (const LogString *message) |
| void | status_clear_warning () |
| void | status_clear_error () |
| ESPDEPRECATED ("Use status_momentary_warning() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_warning(const char *name | |
| void | status_momentary_warning (uint32_t length=5000) |
Set warning status flag and clear it after length ms. | |
| void | status_momentary_warning (const LogString *message, uint32_t length=5000) |
| ESPDEPRECATED ("Use status_momentary_error() without a name. Removed in 2027.5.0", "2026.11.0") void status_momentary_error(const char *name | |
| void | status_momentary_error (uint32_t length=5000) |
Set error status flag and clear it after length ms. | |
| void | status_momentary_error (const LogString *message, uint32_t length=5000) |
| bool | has_overridden_loop () const |
| const LogString * | get_component_log_str () const ESPHOME_ALWAYS_INLINE |
| Get the integration where this component was declared as a LogString for logging. | |
| bool | should_warn_of_blocking (uint32_t blocking_time, uint32_t &threshold_ms_out) |
| Data Fields inherited from esphome::Component | |
| uint32_t | length = 5000) |
Detailed Description
DFRobot "Factory Calibrated Electrochemical Gas Sensor" series (SEN0465 to SEN0476).
The bus variants only send request frames and deliver the answers.
Definition at line 32 of file dfrobot_sen0465_base.h.
Member Function Documentation
◆ compensate_()
|
protected |
Returns NAN when the temperature is outside every range.
Definition at line 262 of file dfrobot_sen0465_base.cpp.
◆ fail_reading_()
|
protected |
Publish unknown on both sensors and set the warning when a reading cannot be used.
Definition at line 157 of file dfrobot_sen0465_base.cpp.
◆ handle_data_()
|
protected |
Definition at line 200 of file dfrobot_sen0465_base.cpp.
◆ handle_no_response_()
|
protected |
Definition at line 147 of file dfrobot_sen0465_base.cpp.
◆ handle_response_()
|
protected |
Definition at line 166 of file dfrobot_sen0465_base.cpp.
◆ next_step_()
|
protected |
Definition at line 136 of file dfrobot_sen0465_base.cpp.
◆ read_response()
|
protectedpure virtual |
Waits for the answer to a request, then calls either handle_response_() or handle_no_response_(), once.
Implemented in esphome::dfrobot_sen0465_i2c::DFRobotSEN0465I2CComponent, and esphome::dfrobot_sen0465_uart::DFRobotSEN0465UARTComponent.
◆ retry_step_request_()
|
protected |
Sends the request again from a scheduled callback; a failed write counts as a failed attempt.
Definition at line 117 of file dfrobot_sen0465_base.cpp.
◆ send_command_()
|
protected |
Sends a request and waits for its answer; returns false when the request could not be sent.
Definition at line 94 of file dfrobot_sen0465_base.cpp.
◆ send_step_request_()
|
protected |
Sends the request of the current step.
Definition at line 104 of file dfrobot_sen0465_base.cpp.
◆ step_failed_()
|
protected |
Definition at line 122 of file dfrobot_sen0465_base.cpp.
◆ write_frame()
|
protectedpure virtual |
Sends one complete request frame.
Implemented in esphome::dfrobot_sen0465_i2c::DFRobotSEN0465I2CComponent, and esphome::dfrobot_sen0465_uart::DFRobotSEN0465UARTComponent.
Field Documentation
◆ alarm_decimals_
|
protected |
Definition at line 85 of file dfrobot_sen0465_base.h.
◆ alarm_threshold_
|
protected |
Definition at line 82 of file dfrobot_sen0465_base.h.
◆ alarm_type_
|
protected |
Definition at line 84 of file dfrobot_sen0465_base.h.
◆ attempts_
|
protected |
Definition at line 87 of file dfrobot_sen0465_base.h.
◆ compensation_
|
protected |
Definition at line 106 of file dfrobot_sen0465_base.h.
◆ gas_name_
|
protected |
Definition at line 81 of file dfrobot_sen0465_base.h.
◆ gas_type_
|
protected |
Definition at line 83 of file dfrobot_sen0465_base.h.
◆ pending_command_
|
protected |
Command whose answer is awaited, 0 when no request is outstanding.
Definition at line 89 of file dfrobot_sen0465_base.h.
◆ setup_incomplete_
|
protected |
A setup step gave up, so the alarm or the mode may not be what was configured.
Definition at line 91 of file dfrobot_sen0465_base.h.
◆ step_
|
protected |
Definition at line 86 of file dfrobot_sen0465_base.h.
The documentation for this class was generated from the following files:
- esphome/components/dfrobot_sen0465_base/dfrobot_sen0465_base.h
- esphome/components/dfrobot_sen0465_base/dfrobot_sen0465_base.cpp
Generated by
 1.12.0